Case study · Magnetic line-following AGV
A Robot That Follows Magnetic Tracks
ESP32-S3: custom Hall-effect PCB, interrupt-driven obstacle detection, MQTT control.
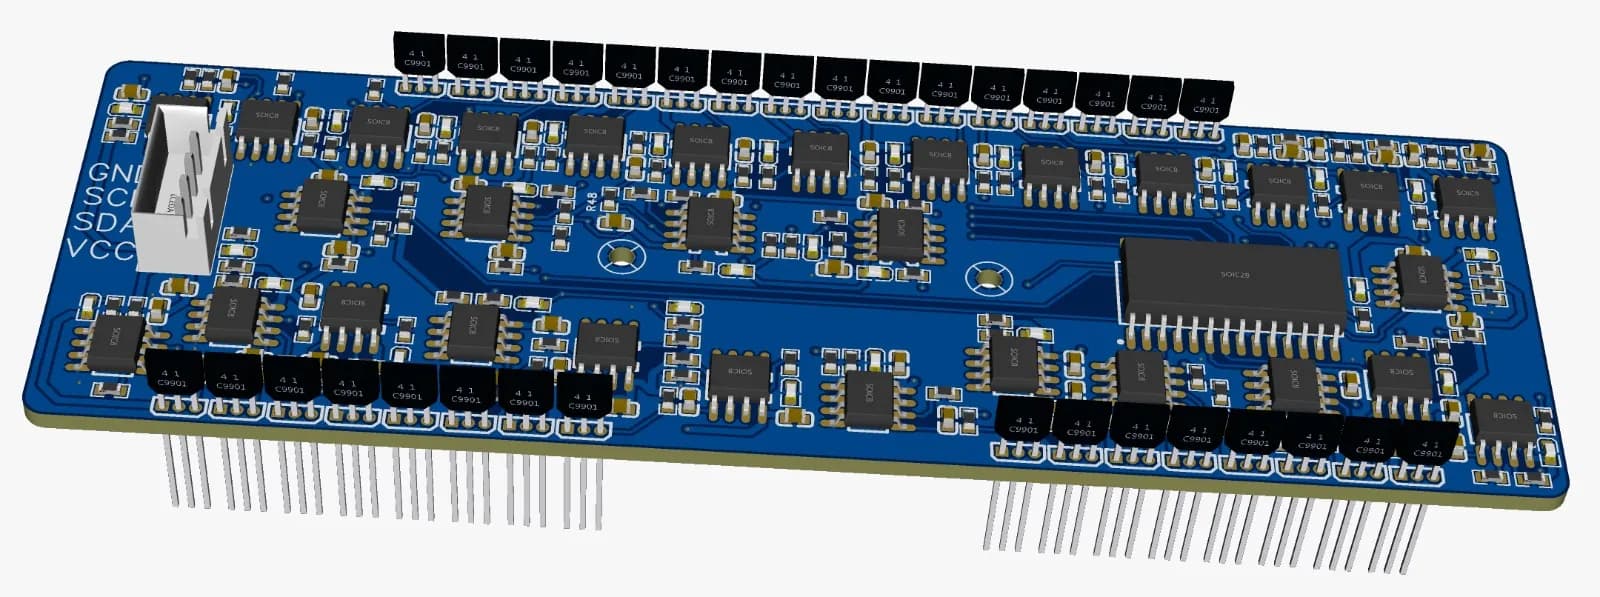
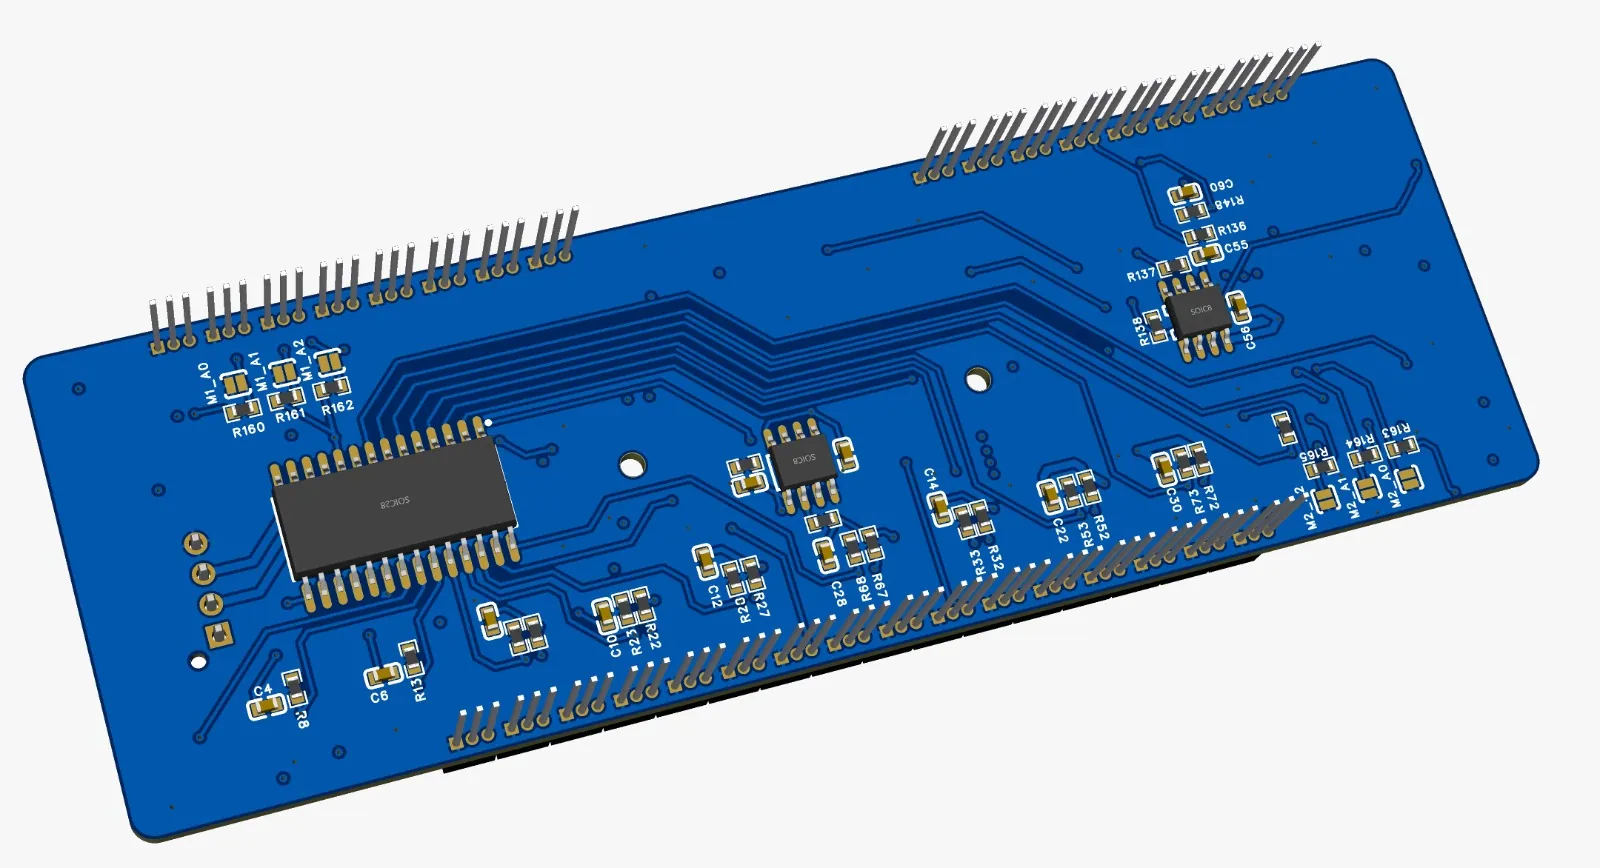
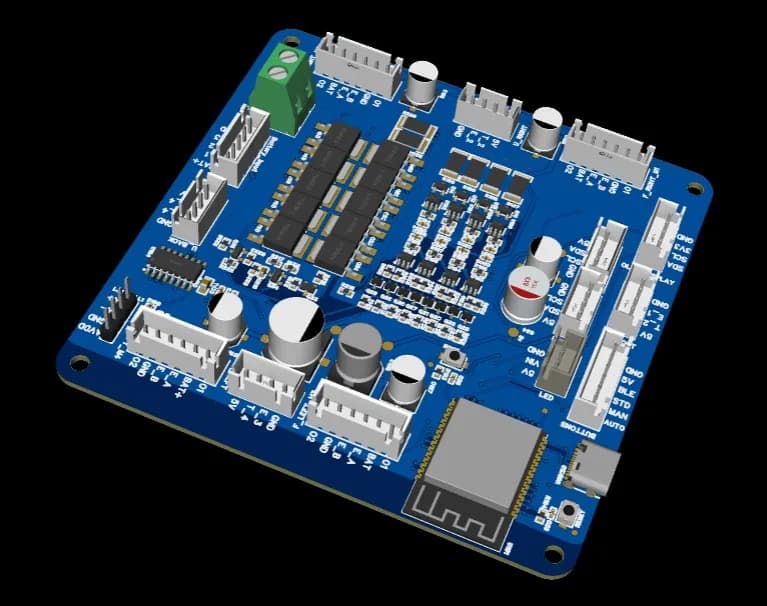
An MQTT-connected automated guided vehicle (AGV) that follows a magnetic line and avoids obstacles, built at MachaDev Engineering in Islamabad, Pakistan, in 2025. I designed a custom Hall-effect sensor PCB for magnetic path tracking and wrote ESP32-S3 firmware with interrupt-driven obstacle detection and MQTT monitoring and control.
- Org
- MachaDev
- Year
- 2025
- Status
- Prototype
- Channels
- CH1CH4CH5
The problem
An automated guided vehicle has to follow a magnetic path, avoid obstacles, and report to a control system.
What I built
- A custom Hall-effect sensor PCB for magnetic path tracking
- Firmware with interrupt-driven obstacle detection
- MQTT monitoring and control
Stack
ESP32-S3 · Custom Hall-effect PCB · Interrupts · MQTT
Results
- Built at MachaDev Engineering (2025)
A row of Hall-effect sensors on the custom PCB reads the magnetic tape under the vehicle so the firmware can keep the AGV on its path. Obstacle detection is interrupt-driven, so the vehicle reacts immediately.
Over MQTT, the AGV reports its status for monitoring and accepts control commands, the same IoT pattern used in industrial automation.
Gallery
Straight from the archive: every photo I could dig up for this build.